Robotic systems · S7
S7: one end locks, the other steps
The dual-ended route combines moving and working: it switches support between cooperative anchor points to reach different work sites. Development covers the arm, end effectors, work-site layout, host interfaces, control and verification conditions.
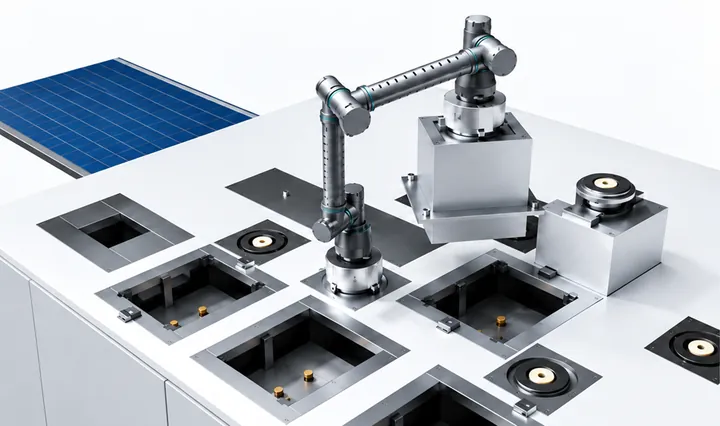 Concept render
Why the support point has to move
A fixed arm covers one workspace. The larger the facility and the more scattered its work sites, the harder it is for one mounting point to reach them all.
Both ends of S7 can act as the base: one end locks onto a cooperative anchor and carries load while the other moves to the next anchor; once that lock is confirmed, they swap roles. Reach grows along the surface without a separate servicing spacecraft.
1.5× · Sped up; not the real task pace · On-screen subtitles are in Chinese
Organising relocation and manipulation tasks
A job breaks into four phases: relocate, anchor and change tools, contact work, then check and withdraw. Every phase has an entry condition: no load-bearing work until the lock is confirmed, no anchor switch until the tool is stowed.
- 1Relocate
Extend reach along cooperative interfaces
- 2Anchor and tool up
Start work once the lock is confirmed
- 3Contact work
Transfer, insert, fasten, replace
- 4Check and withdraw
Confirm the result, return to a safe pose
How the arm, tools and host work together
Anchor, tool and module interfaces are defined separately. The host is responsible for anchor and tool-station layout and load rating, plus power, communications and thermal interfaces. The robot side covers the arm, end effectors, control and mission software. These boundaries are confirmed item by item in mission review.
Current development and verification material
- Mission simulationSurface relocation and fastening simulation
- In developmentJoint-level active compliance development
Data sheet
Dimensions, mass, payload, drives, power and environmental ranges will be published with a configuration version once it is frozen. For now, preliminary information for your platform is available through a mission discussion.
Discuss your platform and task